Our Software Architecture
Three-layer redundancy architecture delivers robust physical AI for autonomy.
AV2.0 Three-Layer Architecture
SuperDrive™’s three-layer architecture is designed to provide redundancy and fail-safe behavior. It runs paid freight operations with a safety driver in Texas today.
The REASONING–REFLEX Dual-Model
REASONING
Leverages a Vision Language Model to interpret complex real-world interactions and generate high-level driving decisions for out-of-ODD edge cases. Acts as strategic driving intelligence, understanding context and making informed decisions for unusual scenarios.
REFLEX
Our transformer-based end-to-end model fuses perception with motion planning to execute rapid, real-time maneuvers. Our network design allows us to provide high-performance models that can rapidly scale up to automotive grade compute.
Multi-Redundancy
Redundant Fallback System
Operates on a secondary edge computer that continuously monitors the primary system’s health. If a fault is detected, it is designed to trigger minimal-risk fallback maneuvers to bring the vehicle safely to a stop.
Remote Operations
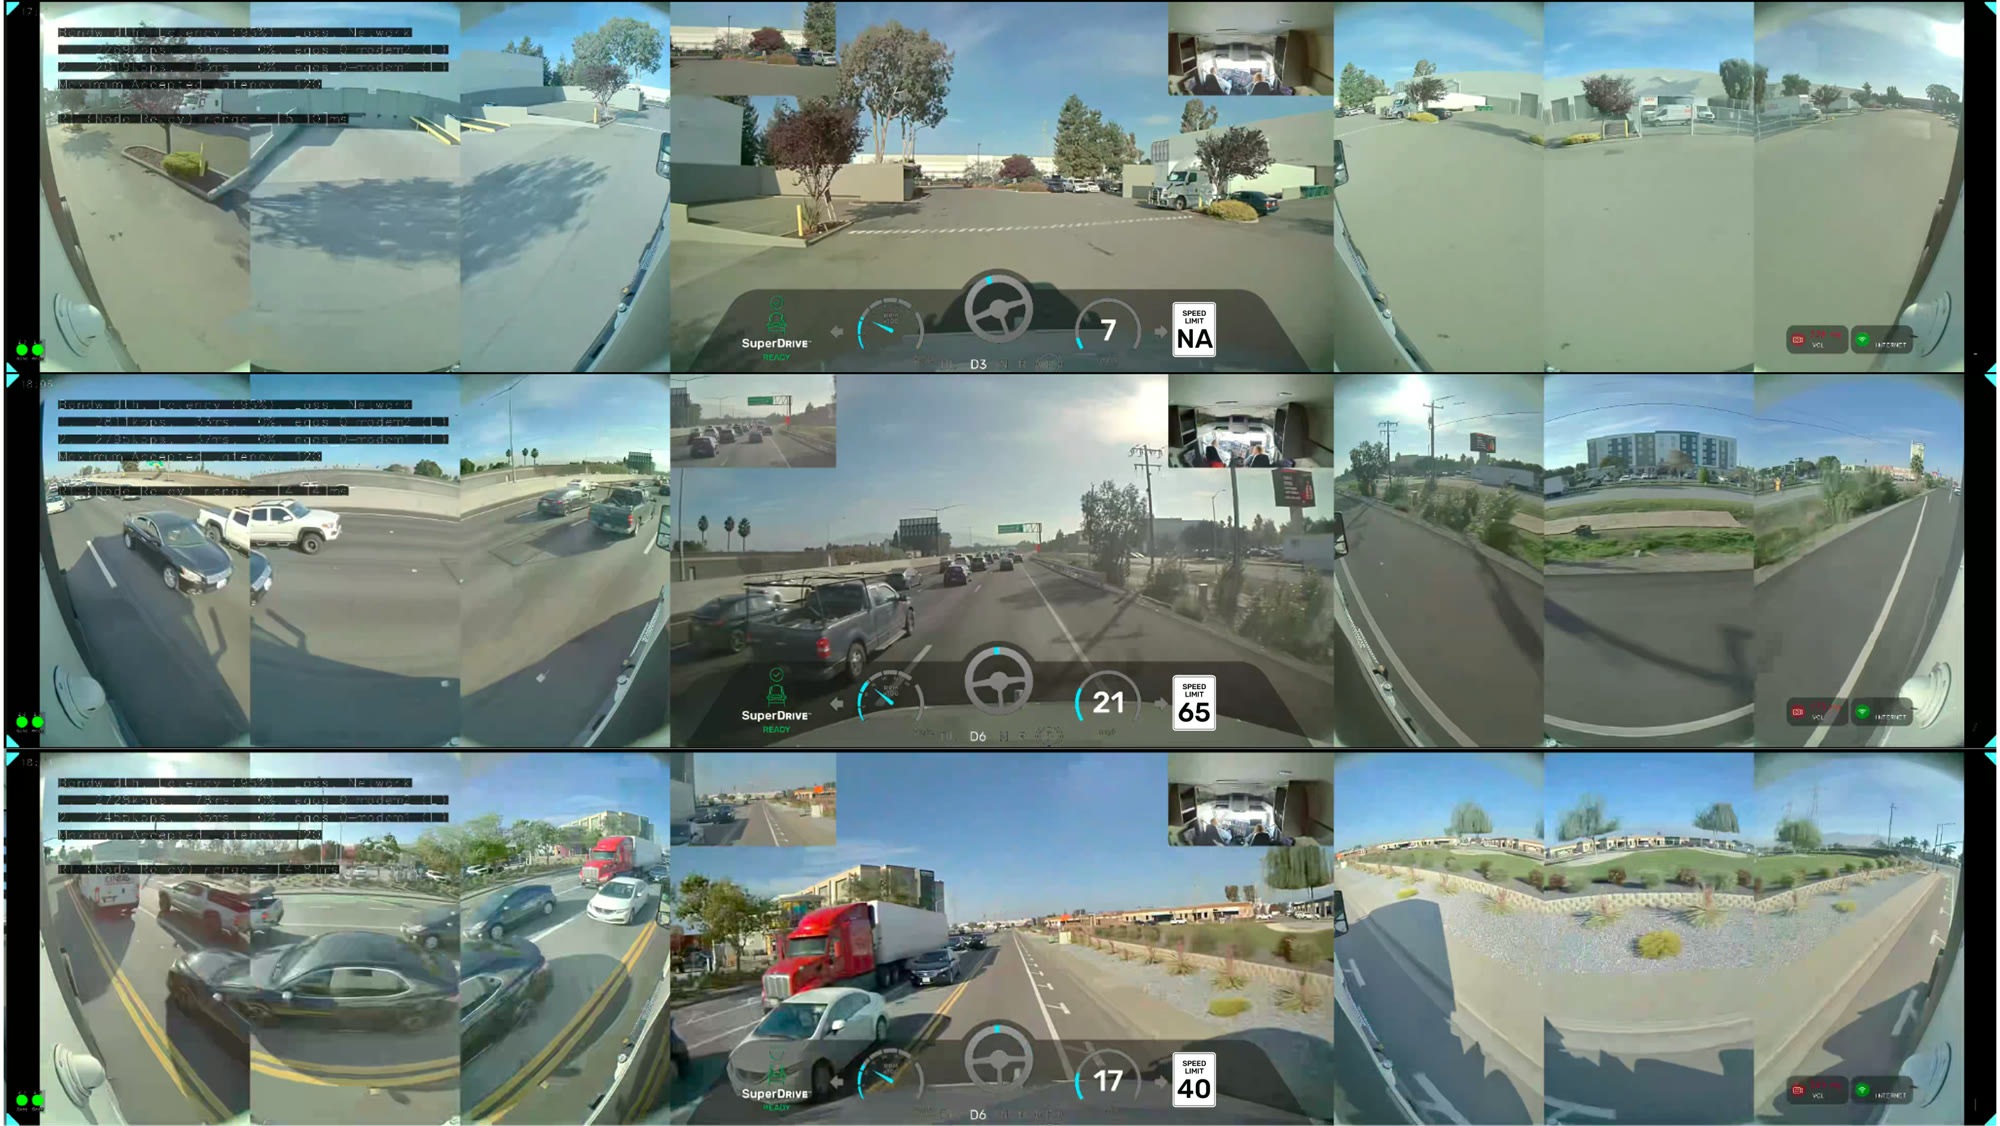
Provides mission control and human-in-the-loop support for scenarios beyond the virtual driver’s Operational Design Domain (ODD), ensuring oversight and intervention when needed. Remote operation activity will be handled by our OEM partners and not by PlusAI directly.
Key Advantages
-
Interpretability
Through semantic reasoning via a Vision Language Model and a defined perception layer, SuperDrive™’s architecture is designed to make driving decisions transparent and explainable for engineers and stakeholders.
-
Traceability
The architecture enables full traceability, making it possible to trace and rectify errors, identify corner cases, and support continual improvement across the entire autonomy stack.
-
Enhanced Safety
Rule-based safety envelopes enable region-specific driving behavior while cloud-based remote operations provide a human-in-the-loop for scenarios beyond the virtual driver’s ODD.
-
Scalability
Zero-shot learning capabilities allow SuperDrive™ to adapt to out-of-sample edge cases, diverse regions, and new vehicle platforms without extensive retraining.
Tech Insights
-
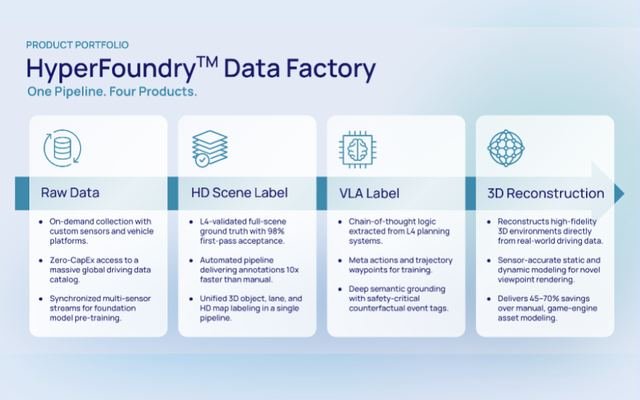 July 14, 2026 Closing the Ground-Truth Gap in Physical AI
-
 July 6, 2026 Threat Modeling for Autonomous Driving: Compliance Isn’t Enough
-
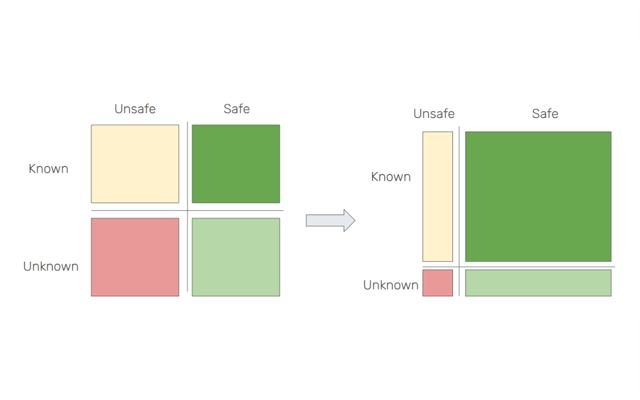 May 21, 2026 PlusAI Safety Analysis Framework (SAF): Turning Unknown Risks Into Solvable Engineering Problems
-
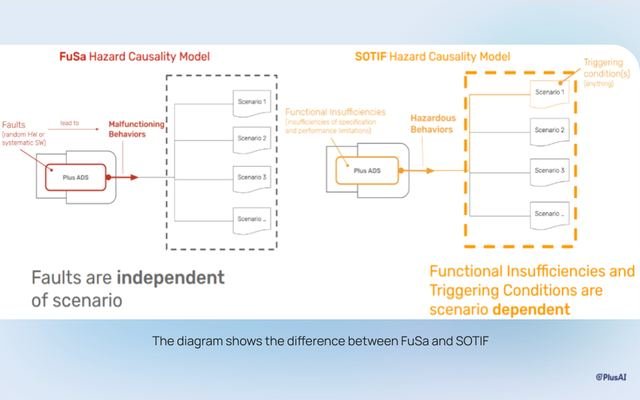 April 9, 2026 PlusAI Safety Analysis Framework (SAF): Cracking the Code on Safety for Autonomous Trucks
-
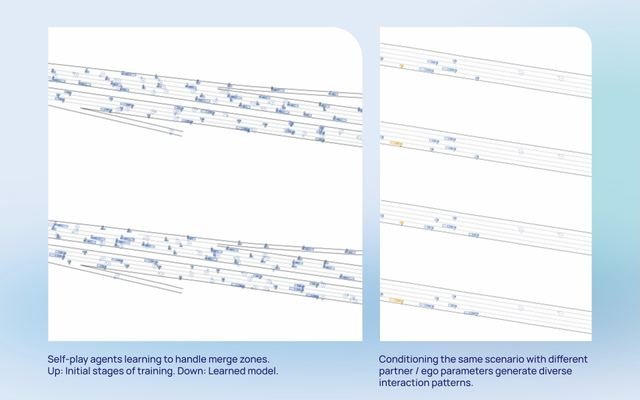 March 23, 2026 Self-Play Reinforcement Learning: How We Train Autonomous Trucks for the Unexpected Moments
-
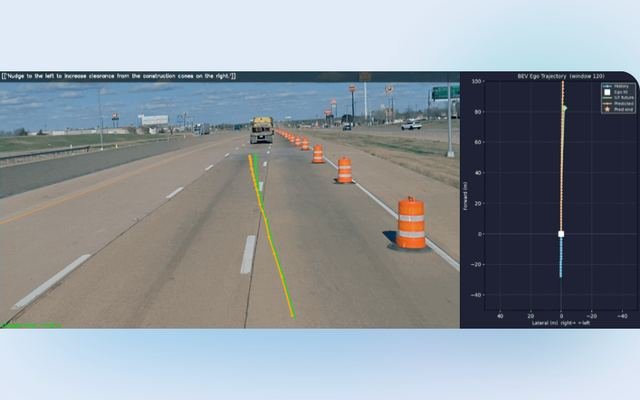 March 16, 2026 The Reasoning Machine